

Reading Room
The Fictionlab Blog
Explore a mix of technical guides, industry insights, and stories from inside our Robot house. Whether it’s engineering deep dives, business analysis, or the history behind our rover competitions, this is where we share our knowledge and culture.
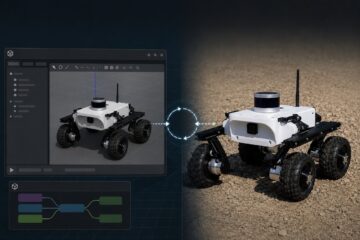
What Is a Robot Digital Twin and How Do You Build One with ROS 2 and Gazebo?
TL;DR: A robot digital twin is a simulated, physics-aware replica of a physical robot that shares its kinematics, sensors, control…
Read more
Mobile Robot Platforms for Perimeter Security and Autonomous Patrol
TL;DR: A security robot UGV for autonomous patrol combines a rugged mobile base, redundant perception (LiDAR, thermal, RGB), and a…
Read more
Robots in Analog Space Missions: How Earth Rovers Prepare Us for Mars
TL;DR: An analog space mission robot is a mobile platform used in Earth-based simulations of lunar or Martian operations, where…
Read more
Construction Site Monitoring with UGVs: Use Cases, Challenges, and Early Results
TL;DR: Construction robot monitoring with unmanned ground vehicles (UGVs) automates progress tracking, BIM-to-as-built comparison, and safety inspection on active sites.…
Read more
Forest and Environmental Research with Mobile Robots: How Field Ecologists Use UGVs
TL;DR: Forest robot research uses unmanned ground vehicles (UGVs) to collect repeatable, georeferenced data under tree canopies where GNSS is…
Read more
Mapping Hazardous Environments: Mines, Volcanoes, and Nuclear Sites
TL;DR: Hazardous environment robot mapping uses mobile robots equipped with LiDAR, depth cameras, and IMU sensors to build 3D maps…
Read more
Search and Rescue Robotics: What Makes a Good Field Platform for SAR Operations
TL;DR: A good search and rescue robot platform combines rough-terrain mobility, resilient communication links, and modular payload integration. For SAR,…
Read more
UGVs in Precision Agriculture: Mapping, Sampling, and Monitoring in the Field
TL;DR: UGV precision agriculture combines unmanned ground vehicles, RTK-GNSS, and multispectral or LiDAR payloads to map fields, collect soil and…
Read more
How Mobile Robots Are Used in Bridge and Infrastructure Inspection
TL;DR: Robot infrastructure inspection can replace some rope-access surveys and scaffolding with mobile ground robots, drones, and crawlers that carry…
Read more
Modular Robotics: Why Swappable Payloads Are the Future of Field UGVs
TL;DR: A modular UGV with swappable payloads lets one chassis serve multiple missions (inspection, mapping, sampling, communications relay) without rebuilding…
Read more
From PCB to Field Robot: What Designing a Custom Controller Board Looks Like
TL;DR: Designing a custom robot controller board for a field UGV is less about picking the fanciest MCU and more…
Read more
How We 3D Print Custom Parts for Leo Rover: Materials, Process, and Tradeoffs
TL;DR: Fictionlab's team uses 3D printed robot parts extensively across the Leo Rover platform - from sensor mounts and antenna…
Read more