

Reading Room
The Fictionlab Blog
Explore a mix of technical guides, industry insights, and stories from inside our Robot house. Whether it’s engineering deep dives, business analysis, or the history behind our rover competitions, this is where we share our knowledge and culture.
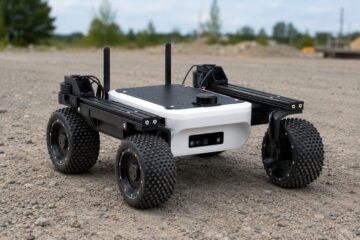
Raph Rover: Built for When Leo Rover Isn’t Enough – A Technical Deep Dive
TL;DR: Raph Rover is Fictionlab's heavy-duty UGV designed for outdoor field robotics where the Leo Rover platform hits its payload,…
Read more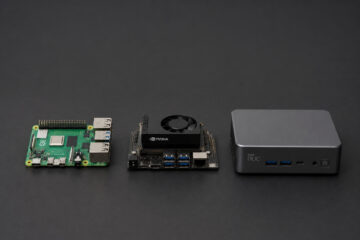
Raspberry Pi vs. NVIDIA Jetson vs. Intel NUC: Choosing the Right Brain for Your Robot
TL;DR: When you compare Raspberry Pi vs Jetson robot computing, the choice comes down to workload, power budget, and software…
Read moreBattery and Power Management for Field Robots: Runtime, Charging, and Hot Swapping
TL;DR: Field robot battery management decides whether your mission finishes or stalls in the middle of a field. You need…
Read more
How to Design a Payload System for a Mobile Robot: Mounting, Weight, and Power
TL;DR: Robot payload design is the engineering discipline of integrating sensors, manipulators, and computing onto a mobile base without breaking…
Read more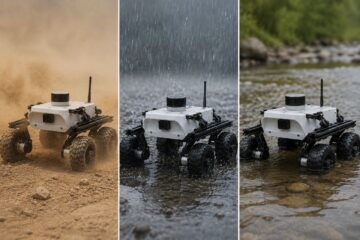
IP Ratings Explained: What IP54, IP65, and IP67 Actually Mean for Your Robot
TL;DR: The IP rating of a robot is a two-digit code defined by IEC 60529 that tells you how well…
Read more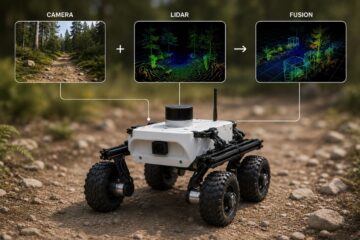
Camera + LiDAR Fusion: How to Build a Perception Stack for an Outdoor UGV
TL;DR: Camera + LiDAR fusion in ROS 2 combines dense color information from an RGB or RGB-D camera with accurate…
Read more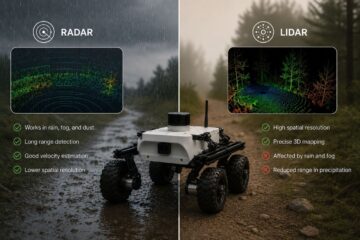
Radar vs. LiDAR for Outdoor Robots: When Rain Wins and When It Doesn’t
TL;DR: In the radar vs lidar outdoor robot debate, neither sensor wins universally. LiDAR gives you centimeter-level geometry and dense…
Read more
How to Properly Calibrate an IMU on a Mobile Robot (And Why Most Teams Skip It)
TL;DR: Proper IMU calibration in ROS 2 means three things: removing static bias from accelerometers and gyroscopes, characterizing noise with…
Read more
Thermal Cameras on Robots: Use Cases, Limitations, and ROS 2 Integration
TL;DR: Thermal cameras on robots let you see heat signatures that visible-light cameras miss: failing PV modules, overheating electrical contacts,…
Read more
How to Process Point Clouds in ROS 2: A Practical Guide for Mobile Robots
TL;DR: Point cloud processing in ROS 2 boils down to four reproducible steps: subscribe to a sensor_msgs/PointCloud2 topic, downsample with…
Read more
What Is a 3D LiDAR and When Should You Use It Instead of 2D?
TL;DR: A 3D LiDAR captures multiple scan layers (often 16 to 128 in mechanical multi-beam models, or a non-repeating 3D…
Read more
RTK GPS on a Field Robot: What It Is, Why You Need It, and How to Set It Up
TL;DR: RTK GNSS (often called RTK GPS, Real-Time Kinematic GPS) is a satellite positioning technique that uses carrier-phase measurements and…
Read more